Quiz · Medium
Conceptual questions on feedback loops, step responses, controller modes, valves and advanced strategies.
In a feedback loop the controller acts on:
The manipulated variable
The process gain
The error between setpoint and measured output
The disturbance measured before the process
Feedback control computes its output from the error e = setpoint - measurement. Acting on a measured disturbance is feedforward.
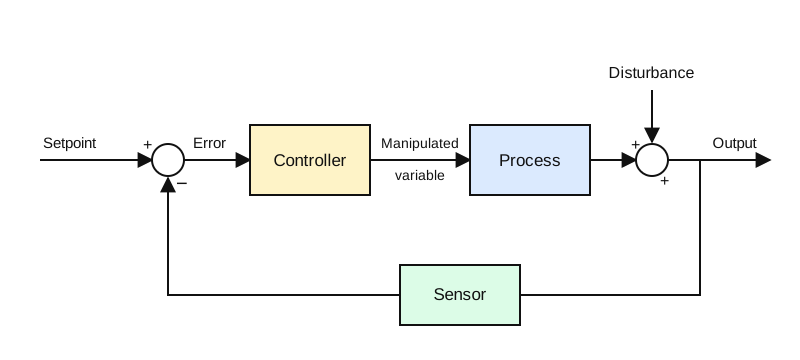
In the block diagram, the block that compares the measurement with the setpoint and computes the manipulated variable is the:
Controller
Process
Sensor
Disturbance
The sensor measures, the process responds; the controller computes the output (the MV) from the error.
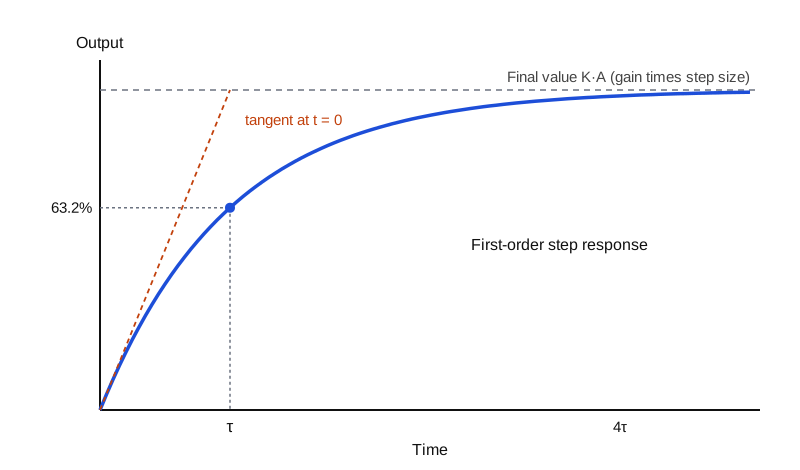
A first-order system reaches what fraction of its final value at t = τ after a step?
95%
86.5%
50%
63.2%
1 - e^-1 = 0.632. After 2τ it is 86.5%, after 3τ 95%.
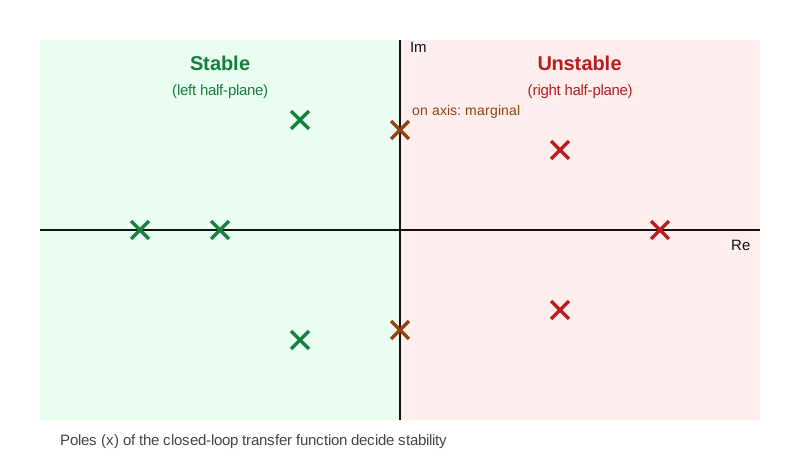
The poles of a transfer function are in the right half-plane. The response to a step input will be:
Constant
Growing without bound
Decaying
Sustained oscillation
Positive real parts give terms like e^(+at): unstable. Left-half-plane poles decay; poles on the imaginary axis are marginal.
An overdamped second-order system has damping ratio:
Equal to 1
Greater than 1
Equal to 0
Less than 1
ζ > 1 gives two real poles and no overshoot. ζ = 1 is critical damping; ζ < 1 is underdamped.
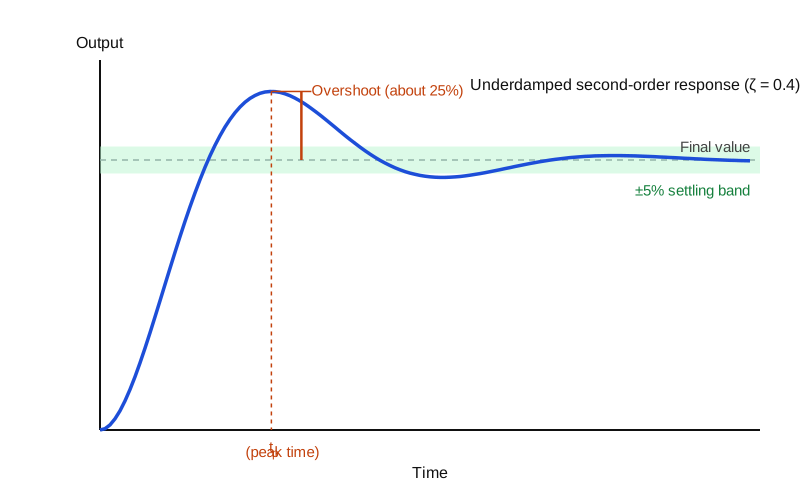
In the second-order step response plotted, what happens to overshoot if ζ is increased from 0.4 to 0.7?
It increases
It decreases
It stays the same
It becomes infinite
Overshoot = exp(-πζ/√(1-ζ²)) falls as ζ rises; at ζ = 0.7 it is about 4.6%, compared with 25% at ζ = 0.4.
Proportional-only control of a self-regulating process generally produces:
An integrating response
Zero offset
Instability at any gain
Offset
A P-only loop needs a nonzero error to keep a nonzero output away from its bias, so a permanent offset remains. Integral action removes it.
Which control mode eliminates offset?
Derivative
Integral
Feedforward alone
Proportional
Integral action keeps changing the output until the error is zero.
Derivative action is least suitable for:
A noisy flow loop
A large heat exchanger
A slow temperature loop
A composition loop with long lags
D amplifies noise because it responds to the rate of change. Flow signals are noisy and the process is fast, so PI is normal.
What does reset (integral) windup cause?
Valve noise
A faster response
A large overshoot after the actuator has saturated
Zero offset forever
While the output is saturated, the integral term keeps growing, and the error must stay negative for a long time to unwind it. That produces large overshoot.
A cooling-water valve on an exothermic reactor should normally be:
Always manual
Quick opening
Air-to-open (fail closed)
Air-to-close (fail open)
On loss of air you want the valve to fail open so cooling continues and the reactor does not run away.
Cascade control is most effective when:
The inner loop is much faster than the outer loop
The inner loop is slower than the outer loop
There are no disturbances
Dead time is zero
The secondary loop must respond fast to reject disturbances before they affect the primary variable; a rough rule is 3 to 5 times faster.
Ideal feedforward control requires:
A faster sensor only
A model of the process and disturbance paths
A derivative term
No model
G_ff = -G_d/G_p, so you need both models. Because models are imperfect, feedforward is paired with feedback trim.
A right-half-plane zero in a process gives:
A pure integrator
Zero gain
Faster response
An inverse response
The output initially moves in the wrong direction (e.g. boiler drum level). It limits achievable controller gain.
True or False: Adding dead time to a loop does not affect stability, since it does not change the gain.
True
False
Dead time adds phase lag (-ωθ) at every frequency while leaving amplitude unchanged. The phase margin shrinks, so stability is reduced.
Which pairing is preferred according to the RGA?
Pair variables with negative λ
Pair variables with λ = 0
Pair variables with λ close to 1
Any pairing is acceptable
λ = 1 means the other loops do not affect the gain; negative λ means the gain changes sign when other loops close, which is dangerous.
Ziegler-Nichols closed-loop tuning begins by:
Using P-only and increasing Kc until sustained oscillation
Putting on integral action only
Removing the sensor
Applying a step to the setpoint
The ultimate gain Ku and ultimate period Pu are found at the stability limit, then the table gives Kc, τI, τD.
Which is TIC on a P&ID?
Temperature indicating controller
Time integrating controller
Torque indicating control
Transmitter indicating controller
First letter: measured variable (T). I = indicating; C = controller.
A tank level with fixed pump outflow behaves like:
A pure delay
A first-order lag
A second-order underdamped system
An integrator
Level accumulates the flow imbalance: A dh/dt = q_in - q_out, so H(s) = Q(s)/(A s). The step response is a ramp.
